Featured
Henrik Christensen shares his views on the impact of the robot revolution and stories from his life in European and US robotics research.
Henrik Christensen shares his views on the impact of the robot revolution and stories from his life in European and US robotics research.
No contact is required with objects by using inexpensive, handheld 'light-reading' device
A brief introduction to localization and mapping, and how these two functions are performed simultaneously during SLAM (Simultaneous Localization and Mapping).
This comprehensive article dives deep into the world of robotics, exploring the history, types, engineering components, applications, and future trends of robots, offering readers an in-depth understanding of how these remarkable machines work and shape our lives.
16 minutes read.
23 minutes read.
19 minutes read.
27 minutes read.
21 minutes read.
40 minutes read.
University
At the Harvard John A. Paulson School of Engineering and Applied Sciences (...
42 Posts
Robotics & Automation
READY Robotics is a robotics software company that vastly simplifies robot ...
24 Posts
Automation Machinery Manufacturing
We are a company in flying robotics, specializing in Non-destructive inspec...
23 Posts
Everyone, guess how fast is it?
The new design could assist the elderly as they age in place at home.
The hospitality industry can leverage the gender characteristics of service robots to influence customers' decisions, according to new research from a team in the Penn State School of Hospitality Management.
Service robots have evolved from simple automated machines to intelligent adaptive systems that can navigate unpredictable environments and interact with humans.
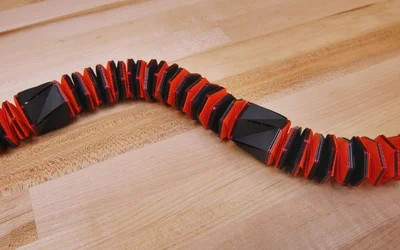
Engineers at Princeton and North Carolina State University have combined ancient paper folding and modern materials science to create a soft robot that bends and twists through mazes with ease.
A research team from ETH Zurich and the University of Zurich (UZH) has developed a novel approach to treating spinal cord injuries: controllable microrobots deliver stem cells directly to the site of an injury, where they promote nerve cell regeneration.
Cornell engineers have developed a robotic collective that behaves less like a machine and more like a material that flows, reshapes and adapts to its environment without centralized control.
From hospital wards to crop fields, from microscopic swarms to biohybrid machines powered by fungi, robotics research at Cornell spans an astonishing range of scale, application and ambition.
Henrik Christensen shares his views on the impact of the robot revolution and stories from his life in European and US robotics research.
No contact is required with objects by using inexpensive, handheld 'light-reading' device
A brief introduction to localization and mapping, and how these two functions are performed simultaneously during SLAM (Simultaneous Localization and Mapping).
Engineers have developed robots capable of self-propulsion without using any motors, servos, or power supply. Instead, these first-of-their-kind devices paddle through water as the material they are constructed from deforms with temperature changes.
As icons and rituals adapt to newer technologies, the rise of robotics and AI can change the way we practice and experience spirituality.
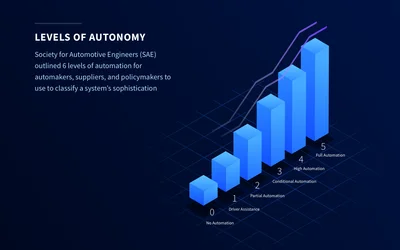
Everything you should know before your next conversation about self-driving cars
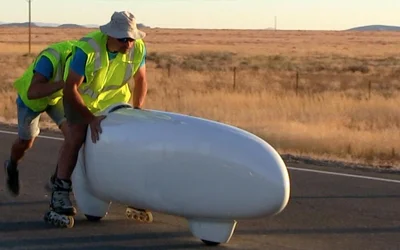
Thanks to software developed bicycle engineers can quickly calculate the most aerodynamic shape for a bike. The software applies artificial intelligence to a set of user-defined specifications. Engineers have used the program to design a bike that they hope will break the world speed record.

3 minutes read
Because your robot’s not going to program itself (yet)
The current state of robotic actuators and mechanical control systems are failing to keep pace with advancing AI software, exploring novel actuator technologies may bridge the gap between man and machine.
Robot’s lightweight, high-power design is the perfect platform to share and play, developers say.
Autonomous driving is no longer sci-fi, it’s become a reality and soon to be hitting our streets. Every week, Autotech companies are announcing their plan for self-driving tech. But, no two autonomous driving technologies are exactly alike.
We are announcing the release of our state-of-the-art off-policy model-free reinforcement learning algorithm, soft actor-critic (SAC). This algorithm has been developed jointly at UC Berkeley and Google, and we have been using it internally for our robotics experiment.
New insights about how euglena navigate their world could lead to advances in the way miniature robots of the future maneuver through the bloodstream or other watery environments.

3 minutes read
Like its predecessor, JackRabbot 2 is learning how to navigate safely through spaces occupied by people, following the rules of human etiquette. What it learns could help it move comfortably among us in the future.
3 minutes read
Meet Tribot, the three-legged origami robot designed and built by EPFL scientists. Tri- for three legs and -bot for robot, this super-light critter fits in the palm of your hand, is cheap to build, runs on less than one watt of power, and may one day be deployed in mass for search and rescue mission