ROVs & AUVs
How Deep Trekker Enables Underwater Dead Reckoning with Xsens MTi
How does connector design influence UAV performance in demanding environments? Harwin explores high-reliability connectors for next-generation UAVs.
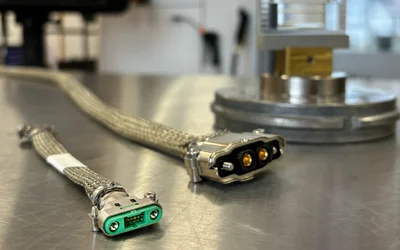
An interview with Ryan Smart, VP of Product at Harwin, discussing the challenges of shielding in high-reliability connectors, high-current design trends, and the hybrid power-and-signal connector layouts.
Engineers Wiki. Most Asked Questions.
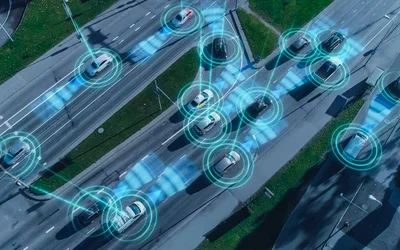
Lidar SLAM lets a robot, vehicle, or handheld scanner map an unknown space while tracking its own position inside it. This guide discusses the processing pipeline, compares nine lidar SLAM and odometry algorithms, from GMapping to lidar-inertial and neural methods, and shows how to choose sensors
Verilog vs VHDL: A Comprehensive Comparison
16 minutes read.
ORGANIZATIONS. SHAPING THE INDUSTRY.
InDro Robotics
Robotics and Drones
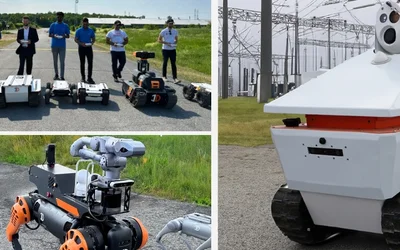
We empower R&D by providing the computational power, ROS packages, payloads & functionality for your unique use case.
14 Posts
Cloud Ground Control
Drone Fleet Management Software
Cloud Ground Control is a cloud based command and control solution for oper...
7 Posts
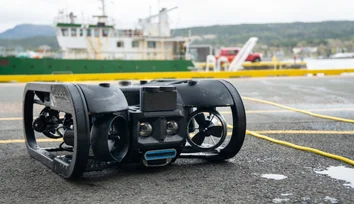
TAGGED WITH remotely operated vehicles (rovs)
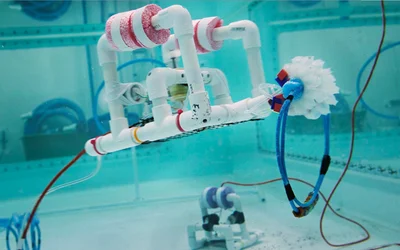
Launched by MIT Sea Grant, SeaPerch and SeaPerch II have had a big impact on young learners interested in ocean science and engineering.
How to Maximize Your Robot Without Blowing Your Budget
Discover how Deep Trekker rigorously tests and evaluates IMU technologies, comparing MEMS and FOG systems to ensure precise underwater navigation for ROVs.
TAGGED WITH aquatic exploration
Learn more about what sonar is and its many uses. Read about its applications, technologies, principles, and more.
Learn about Deep Trekker’s proprietary BRIDGE technology and how it enables you to control your Deep Trekker ROV from any device, and so much more.
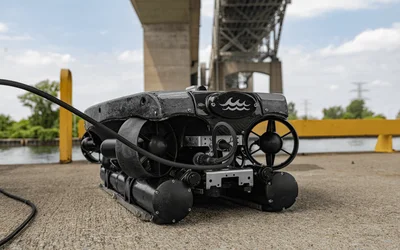
Everything you need to know about Dead Reckoning for underwater navigation.
In this episode, we discuss how CalTech researchers have created bionic jellyfish to help us explore the oceans and better understand the impacts of climate change.
Latest Posts
How Deep Trekker Enables Underwater Dead Reckoning with Xsens MTi

4 minutes read
How does connector design influence UAV performance in demanding environments? Harwin explores high-reliability connectors for next-generation UAVs.
An interview with Ryan Smart, VP of Product at Harwin, discussing the challenges of shielding in high-reliability connectors, high-current design trends, and the hybrid power-and-signal connector layouts.
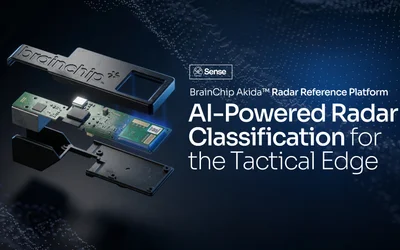
Adding Intelligence to Radar with the BrainChip Real-Time Micro-Doppler Classification
CBC Interview: InDro Robotics CEO Philip Reece on the New Federal Budget & Technology

4 minutes read
How standardized electronic identification will enable high-volume, complex drone operations.
4 minutes read
The Companies and Concepts Redefining Tomorrow's Industries
5 minutes read
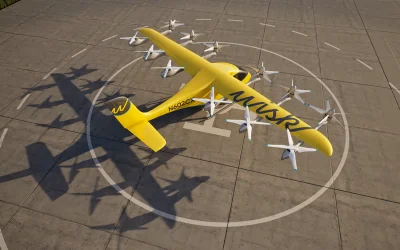
JR Hammond and CAAM advocate the path toward Canada's Advanced Air Mobility Future.
5 minutes read
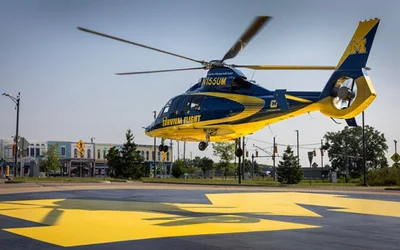
The newly designated airspace links U-M's autonomy testbed with Detroit's innovation district.

5 minutes read
What the new drone regulations mean for you and your drone operations.
5 minutes read
Launched by MIT Sea Grant, SeaPerch and SeaPerch II have had a big impact on young learners interested in ocean science and engineering.
How to Maximize Your Robot Without Blowing Your Budget
6 minutes read
Discover how Deep Trekker rigorously tests and evaluates IMU technologies, comparing MEMS and FOG systems to ensure precise underwater navigation for ROVs.

7 minutes read
Discover the vital role of underwater positioning in marine science, and how remotely operated vehicles (ROVs) are leading the way in location tracking.
12 minutes read
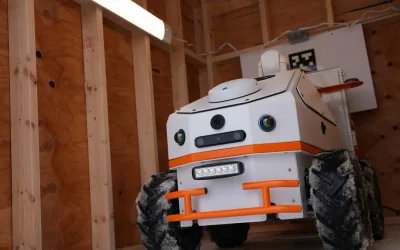
An outdoor enclosure that keeps Sentinel protected from harsh weather, while allowing for wireless recharging.
5 minutes read