Lidar vs Radar: Key Differences, Specs and Uses in Autonomous Driving and Speed Enforcement
Lidar measures distance with laser light; radar with radio waves. This guide compares the two technologies using published figures for wavelength, range, resolution, velocity, weather, and cost, and discusses suitable applications for each.

Last updated on 23 Oct, 2026. 15 minutes read
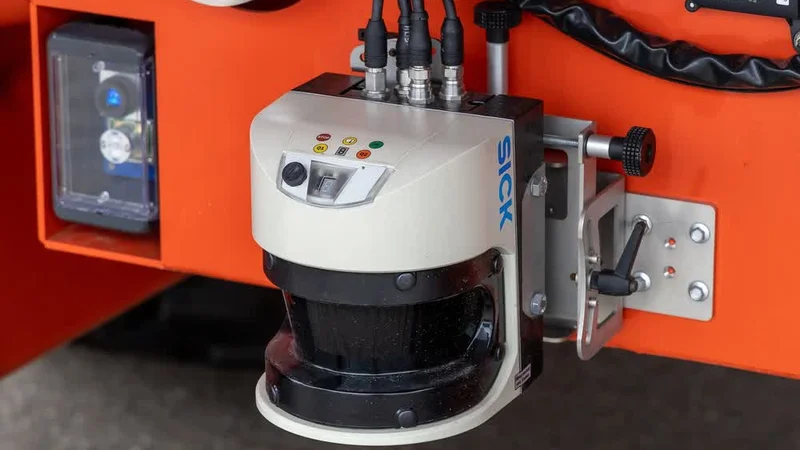
A LiDAR sensor is more compact mountable on a vehicle for driver assistance
Key Takeaways
Automotive lidar commonly uses 905 nm near-infrared laser light. Automotive radar uses millimeter waves, including the 76 to 81 GHz band, with wavelengths of about 4 mm.
Lidar resolves finer detail with angular resolution as precise as 0.1° × 0.1°, while a 4D imaging radar vendor claims azimuth resolution of less than a degree.
Radar measures relative velocity directly from the Doppler shift and can work in extreme weather conditions, while lidar perception deteriorates in foggy conditions.
4D imaging radar adds elevation, and FMCW lidar measures a velocity for every point.
Waymo's 6th-generation Driver fuses 13 cameras, 4 lidar, and 6 radar. Tesla is the best-known exception and relies primarily on cameras.
Introduction
Lidar vs radar is a highly sought-after comparison. Primarily, these technologies are compared for two reasons. If you design autonomous vehicles or ADAS features, you want to know which sensor sees farther, sharper, and more reliably. If a police officer has just clocked your speed, you want to know which kind of gun was pointed at you.
Both technologies work on the same principle. They emit energy, catch the reflection, and measure it. Lidar can be described as a remote sensing detection system. It works on the same principle as radar but uses light from a laser.
So, what differentiates the two technologies? The difference lies in the kind of energy that both systems use:
Lidar (light detection and ranging) uses light in the form of a pulsed laser to measure ranges.[1]
Radar (radio detection and ranging) radiates electromagnetic waves and processes the reflections scattered back by targets to establish their range.[2]
This radar vs lidar guide starts with the numbers, then explains how each sensor works, what 4D imaging radar and FMCW lidar change, how the two are combined through sensor fusion, and how the comparison plays out in autonomous driving and in speed enforcement.
A Quick Lidar vs Radar Comparison
The table compares the two sensor types on published figures. Range and resolution values belong to specific products, not to the technology as a whole, so read them as representative examples.
Parameter | Lidar | Radar |
Signal | Laser light, pulsed in time-of-flight lidar and continuous in FMCW lidar;[1][3] | Radio waves; automotive radar uses short-wavelength millimeter waves[4] |
Wavelength or frequency band | 905 nm common in autonomous vehicles;[2] 865 nm (Ouster OS1);[5] 1550 nm (Luminar)[6] | Automotive: 24, 60, 77 and 79 GHz;[2] 76 to 81 GHz is a wavelength of about 4 mm.[4] Airport surveillance: 2,700 to 2,900 MHz (S-band)[7] |
Range (example products) | 90 m at 10% reflectivity and 170 m at 80% (Ouster OS1, 1024 @ 10 Hz mode);[5] 110 m at 10% and 180 m at 50% with native 0.1° pixels in its region of interest. | 300 m (Continental ARS540 4D imaging radar);[8] 60 nautical miles, about 111 km (primary radar of the FAA's ASR-11 airport surveillance radar)[7] |
Angular resolution | 0.088° horizontal (Ouster OS1 in 4096 horizontal resolution mode);[5] 0.1° × 0.1° with native pixels (InnovizOne)[9] | Azimuth resolution under one degree claimed for 4D imaging radar (NXP)[10] |
Range resolution or precision | Range precision within 7 cm or 0.2% of ground truth (InnovizOne);[9] typical range precision ±0.25 cm to ±1.5 cm at one standard deviation (Ouster OS1)[5] | Spatial resolution typically on the order of 0.5 m for long-range and 0.1 m for short-range vehicular radar;[11] 3.75 cm with a 4 GHz chirp[4] |
Velocity measurement | Pulsed lidar compares multiple returns, according to FMCW developer Aurora; FMCW lidar measures velocity per point from the Doppler shift[3] | Measured directly from the Doppler shift, or from the phase difference between two chirps[2][4] |
Weather | Harsh weather such as fog and snow can degrade 905 nm lidar performance by 25%;[2] below 40 m visibility, perception limited to under 25 m in a 2018 test of four lidars[12] | Impervious to adverse weather conditions such as fog, snow and cloud[2] |
Lighting | Works day and night[2] | Independent of illumination[2] |
Cost | Higher but falling: automotive lidars were in the US $10,000 range in 2017;[6] Waymo cites significant industry cost reductions over the five years to 2026[13] | Lower; "more mature and lower cost" than lidar, according to Xilinx in 2020[8] |
Output | Dense 3D point cloud[1] | Range, angle and velocity per detection;[4] 4D imaging radar adds elevation[8] |
Lidar range depends heavily on how reflective the target is and on the operating mode. The same Ouster OS1 is rated at 90 m on a 10% target and 170 m on an 80% target, both in its 1024 @ 10 Hz mode under 100 klx sunlight.[5]
The InnovizOne's 250 m is its maximum range at 10% reflectivity with native 0.1° pixels inside the Eagle configuration's region of interest, the datasheet gives 110 m.[9] And precision is not resolution. Range resolution is the ability to distinguish between two or more objects,[4] while the OS1's ±0.25 cm to ±1.5 cm is a typical range precision, quoted at one standard deviation.[5]
Lidar vs Radar Cost
Lidar and Radar cost figures change quickly because of evolving techniques. In 2017, IEEE Spectrum reported that the biggest contributor to the cost of today's US $10,000-range automotive lidars was their complex opto-mechanical scanners. The same article reported that three companies had announced solid-state lidars with projected prices as low as $100.[6]
In February 2026, popular Lidar manufacturer Waymo claimed its 6th-generation lidar leverages significant cost reductions over the last five years, especially as affordable lidar increasingly appears in consumer vehicles.[13] Moreover, solid-state lidar also generally costs less than mechanical lidar.[2]
When it comes to radar costs, in 2020, the senior director of automotive at Xilinx mentioned that radars are more mature and cost-efficient than lidars, which is perhaps their biggest advantage.[8] Waymo says its own radar also benefits from industry-wide cost reductions, as radar chipsets have become "more sensitive and affordable".[13]
How Lidar Works
Lidar emits laser pulses, which reflect off target objects. The instrument detects the reflections, and the interval between emission and return gives the distance.[2] This is the time-of-flight principle. As the lidar scans its surroundings, it builds a 3D representation of the scene in the form of a point cloud.[2]
A worked example shows that at the speed of light at 3 × 10^8 m/s,[2] a return that arrives 1 µs after the pulse left corresponds to a round trip of 300 m, so the target is 150 m away. Every point in the cloud is one such measurement.
For airborne mapping, NOAA describes a lidar instrument as principally a laser, a scanner, and a specialized GPS receiver.[1]
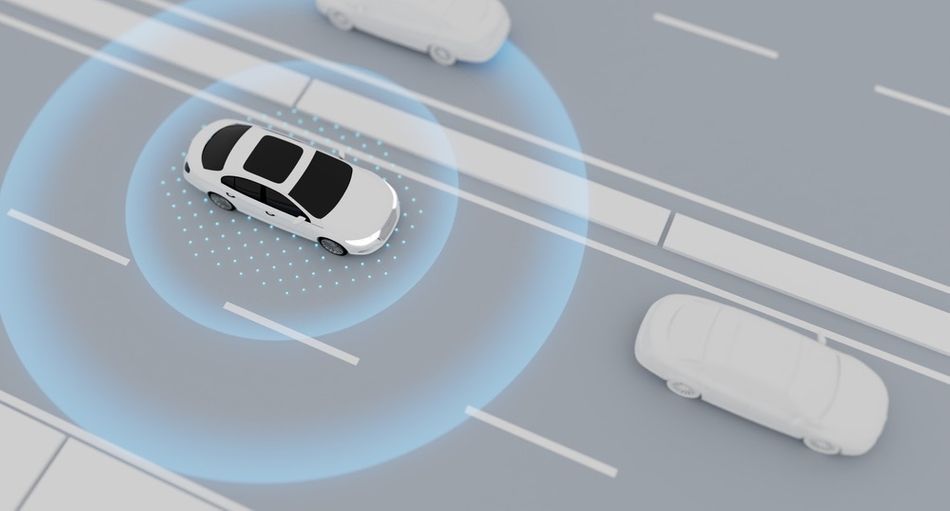 Fig 1: An illustration of an autonomous car using LIDAR to detect obstacles
Types of Lidar Systems
1D, 2D and 3D lidar. A 1D sensor measures only distance. A 2D lidar adds angle information, and a 3D lidar fires laser beams across the vertical axis to measure elevation as well. For autonomous driving, sensors with 64 or 128 channels are common.[2]
Mechanical lidar. High-grade optics and rotary lenses, driven by an electric motor, steer the laser beam and can cover 360° horizontally.[2]
Solid-state lidar. No rotating lenses, which avoids mechanical failure. Solid-state units also generally cost less than mechanical ones. The trade-off is a narrower horizontal field of view, typically 120° or less.[2]
Flash lidar. Continental's HFL110, a solid-state 3D flash lidar that Continental describes as a short-range sensor, was released to series production in November 2021 with a 50 m range and a 120° × 30° field of view.[14]
FMCW lidar. Measures range and velocity from a continuous beam whose frequency changes in a known pattern.[3]
Suggested Reading: LiDAR: making significant inroads into our factories and warehouses
Lidar Wavelengths: 905 nm vs 1550 nm
In autonomous vehicle applications, Lidar sensors typically use the Class 1 laser. It uses a 905 nm laser, which undergoes lower absorption by water, as compared to 1550 nm sensors.[2]
But since the eye is opaque to 1550 nm light, Luminar preferred this wavelength to incorporate 40 times more powerful lasers without endangering the retina.[6]
Moreover, silicon sensors do not respond at 1550 nm, but room-temperature indium gallium arsenide sensors do.[6]
How Radar Works
Radar radiates electromagnetic waves into an area of interest and processes the scattered reflections to establish range. It uses the Doppler property of those waves to determine the relative speed and position of obstacles.[2]
The Doppler shift is
fd = 2 × Vr / λ,
where Vr is the target's relative speed, and λ is the wavelength of the transmitted signal. When a target moves toward the radar, the frequency of the received signal increases.[2]
For example, at 77 GHz, λ is about 3.9 mm. A car closing at 30 m/s (108 km/h) produces a Doppler shift of 2 × 30 / 0.0039, or roughly 15.4 kHz. The radar derives the target's relative speed from that shift.
Suggested Reading: What Is Radar? How It Works, Frequency Bands, Types, and Uses
Pulsed Radar vs FMCW mmWave Radar
Traditional pulsed radar transmits short pulses periodically. FMCW radar transmits a frequency-modulated signal continuously in order to measure range as well as angle and velocity.[4] In an FMCW mmWave radar:
Range comes from an intermediate frequency (IF) signal. A mixer combines the transmitted and received chirps, and the IF signal's frequency is the difference between their instantaneous frequencies.[4]
Velocity comes from the phase difference between two chirps. Velocity resolution is inversely proportional to the frame time.[4]
Angle is estimated with at least two receive antennas. Spacing them half a wavelength apart gives the widest angular field of view, ±90°.[4]
Texas Instruments notes that a radar operating at 76 to 81 GHz, with its wavelength of about 4 mm, can detect movements as small as a fraction of a millimeter.[4]
Automotive Radar Frequency Bands
In a review, Yeong et al. list commercial radars operating at 24, 60, 77 and 79 GHz. Compared with 79 GHz sensors, 24 GHz sensors have more limited range, velocity and angle resolution, and the review predicted they would be phased out.[2]
In the US, the FCC moved in 2017 to authorize the entire 76 to 81 GHz band for vehicular radars. A 1995 decision had made only 76 to 77 GHz available.[11] The FCC's order describes two classes of vehicular radar:
Long-range radar (LRR) uses up to 1 GHz of bandwidth, typically with a spatial resolution on the order of 0.5 m. It underpins features including collision avoidance and adaptive cruise control.[11]
Short-range radar (SRR) uses up to 4 GHz of bandwidth, typically with a spatial resolution on the order of 0.1 m. Applications listed in the order include blind spot detection, parking aids and pedestrian detection.[11]
4D Imaging Radar and FMCW Lidar
The classic trade-off is that lidar sees shape and radar sees speed. Two newer technologies attack that trade-off from opposite ends.
4D Imaging Radar
Conventional radar measures range, speed, and azimuth. On the other hand, a 4D imaging radar can also measure elevation.[8][10]
EE Times reported in September 2020 that Continental had announced the automotive industry's first production-ready 4D imaging radar, the ARS540, expected to ship in passenger vehicles in 2021. The article gives the ARS540 a 300 m range and a ±60° field of view, and names detecting a traffic jam under a bridge as an example of the complex scenarios it targets.[8]
Continental's ARS540 product page now redirects to AUMOVIO, which lists the ARS640 as the successor to the ARS540.[15]
According to NXP,4D imaging radar reaches azimuth resolutions under one degree and detection ranges exceeding 300 m.[10]
FMCW Lidar
FMCW lidar emits a continuous beam whose frequency changes in a known pattern. It then mixes the return signal with a local reference beam. This technique is widely used alongside radar and cameras on self-driving trucks.[3]
Since moving objects impose a Doppler shift on the returning laser light, every point in the point cloud carries its own instantaneous velocity. It allows the systems to differentiate a stopped vehicle from one merging across a lane without waiting to compare multiple returns.[3]
Furthermore, vendors add claims worth testing on your own targets:
Velocity and range: Aeries II measures the velocity of each point with centimeter-per-second precision, at up to 500 m, over a maximum field of view of 120° × 30°.[16] The next generation of FirstLight lidar can reach up to one kilometer.[3]
Interference: Aeries II has freedom from interference from other lidar sensors and from the sun when it is in the field of view.[16]
Weather. Aeva claims a greater ability to see through airborne particulates such as dust, fog, rain, and snow.[16]
When combined, FMCW lidar brings per-point velocity to lidar, and 4D imaging radar brings elevation to radar.
Sensor Fusion Combining Cameras, Radar and Lidar
Cameras add color and texture information, so they are useful for traffic sign recognition, traffic light recognition, and lane marking detection. Because camera performance depends heavily on environmental conditions and illumination, image data are often fused with radar and lidar data.[2]
The research literature describes three main sensor combinations for obstacle detection:
Camera-lidar
Camera-radar
Camera-lidar-radar
According to a survey, camera-radar is the most used combination, followed by camera-lidar-radar and then camera-lidar. The camera-radar pairing gives high-resolution images plus distance and velocity; adding lidar gives resolution at greater range and improves the safety redundancy of the system.[2]
Yeong et al. describe three primary fusion approaches:[2]
Fusion level | What is fused | Strengths and weaknesses |
High-level (HLF) | Each sensor runs its own detection or tracking; the results are fused | Lower relative complexity, but lower-confidence classifications are discarded, for example when obstacles overlap |
Mid-level (MLF) | Features extracted from each sensor, such as color from images or location features from radar and lidar | An abstraction level between LLF and HLF, also called feature-level fusion |
Low-level (LLF) | Raw data from each sensor, at the lowest level of abstraction | Retains all information, but requires precise extrinsic calibration and temporal calibration of the sensors |
Lidar vs Radar in Autonomous Driving
In 2019, the nuScenes authors wrote that most autonomous vehicles carry a combination of cameras and range sensors such as lidar and radar.[17] Here is where three of the best-known programs stand now.
Waymo
Waymo's 6th-generation Driver uses 13 cameras, 4 lidar, 6 radar, and an array of external audio receivers. The suite provides overlapping fields of view all around the vehicle, up to 500 m away, day and night, in a range of weather conditions, at a significantly reduced cost.[18]
Waymo's description of how the sensors divide the work is a useful summary of the lidar vs radar trade-off:[13]
Cameras interpret semantic details such as traffic light colors and road signs.
Lidar uses laser beams to paint a 3D point cloud. Short-range lidars add accurate distance to camera imagery, with centimeter-scale range accuracy.
Imaging radar tracks the distance, velocity, and size of objects in all lighting and weather conditions.
Lidar and radar together provide redundancy where a camera's view may be limited.
Tesla
Tesla is the best-known exception to the fusion approach. At Tesla's first Autonomy Day event in April 2019, its cars drew on radar, GPS, maps, and ultrasonic sensors but not lidar.[19]
In the pursuit of a camera-based autopilot system, also known as Tesla Vision, Tesla removed the radar too. Its subsequent models, like the Model 3 and Model Y vehicles built for the North American market, would no longer be equipped with radar.[20]
At the time, Model S, Model X, and non-North American vehicles kept their radar.[20] Tesla's annual report describes its approach to self-driving as "using primarily vision-based technologies",[21] and its support page for Full Self-Driving (Supervised) describes on-board cameras with 360-degree visibility. The same page states that these features do not make the vehicle autonomous.[22]
Which Is More Accurate for Autonomous Vehicles?
Neither sensor wins on every axis:
Geometry: lidar. Datasheets list centimeter-level range precision and angular resolution such as 0.1° × 0.1° with native pixels.[5][9]
Velocity: radar, unless the lidar is FMCW. Radar derives relative speed from the Doppler shift.[2]
Weather and darkness: radar. It is impervious to adverse weather conditions and independent of illumination.[2]
Static objects: a radar weak point. Yeong et al. list distinguishing static, stationary objects among radar's challenges.[2]
Waymo, which now runs fully autonomous operations, uses all three sensor types rather than choosing one.[18][13]
Suggested Reading: Autonomous Vehicle Technology Report
Lidar vs Radar Speed Guns
Police use both technologies for speed measurement. In the US, NHTSA maintains technical specifications for radar and lidar speed-measuring devices.[23] NHTSA's LIDAR Speed-Measuring Device Performance Specifications are published as report DOT HS 809 811, dated March 2013.[24]
The practical difference is beam width. Kustom Signals, which makes speed enforcement equipment, says radar speed guns emit broad waves, which makes them more effective on roads with low traffic than on crowded city streets, where the waves bounce off many cars.
Lidar speed guns use narrow light pulses that let officers target specific vehicles, with great accuracy even in heavy traffic. The same manufacturer credits radar with consistent performance in any weather condition and low cost, and names bad weather and long distances as factors that affect lidar.[25]
According to IEEE Spectrum in 2017, police lidar guns use 905 nm lasers because they don't need long range, the lasers are cheap, and the guns can use inexpensive silicon detectors.[6]
Speed gun | Beam | Best Use | Main limits |
Radar | Broad waves[25] | Low-traffic roads or deserted highways; any weather[25] | Crowded streets, where the beam reflects off many cars[25] |
Lidar | Narrow light pulses, 905 nm[6][25] | Targeting one vehicle, even in heavy traffic[25] | Bad weather and long distances[25] |
For you as a driver, a lidar reading is aimed at one vehicle, while a radar beam covers more of the road.
Applications in Air Traffic Control, Weather and Mapping
Radar in Air Traffic Control and Weather Monitoring
The FAA's ASR-11 airport surveillance radar is an integrated primary and secondary radar system that has been deployed at terminal air traffic control sites, with a six-level, National Weather Service-calibrated weather capability.[7] Its primary radar is a 60 nautical mile (about 111 km) S-band radar operating at 2,700 to 2,900 MHz. It transmits electromagnetic waves, measures the time for the beam to return and its azimuth, and combines distance and azimuth to locate each aircraft.[7]
For weather monitoring, NEXRAD is a network of 160 high-resolution S-band Doppler weather radars, jointly operated by the National Weather Service, the FAA and the US Air Force. It detects precipitation and wind, and its data can be processed to map precipitation patterns and movement.[26]
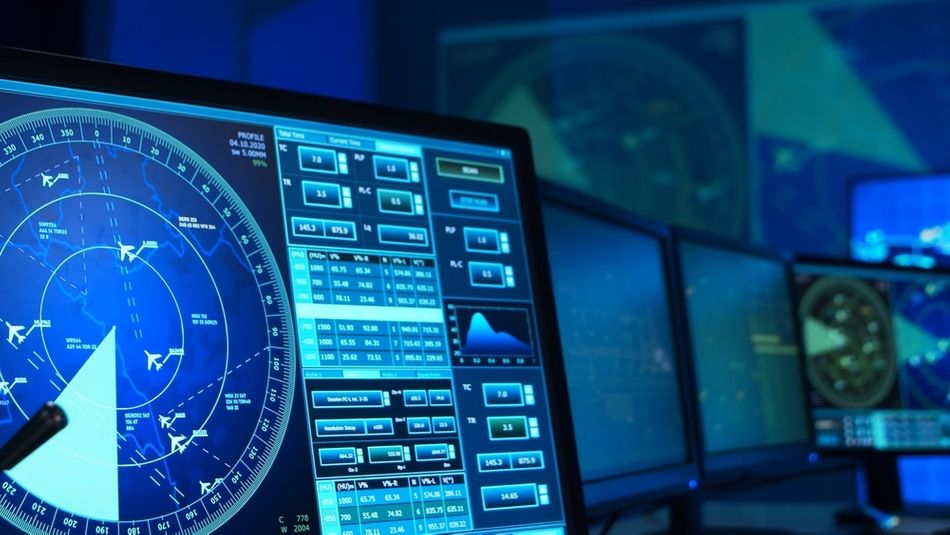 Fig 3: The display of an air-traffic control interface
Lidar in Mapping, Environmental Monitoring and Forestry
Airplanes and helicopters are the most commonly used platforms for acquiring lidar data over broad areas.[1] Topographic lidar typically uses a near-infrared laser to map the land, while bathymetric lidar uses water-penetrating green light to also measure seafloor and riverbed elevations.[1] NOAA lists uses including:
3D mapping and elevation models. Point clouds are used to generate digital elevation models, canopy models, building models, and contours.[1]
Coastal science. Lidar supports inundation and storm surge modeling, shoreline mapping, emergency response, and coastal vulnerability analysis.[1]
Environmental monitoring. Bathymetric lidar data is used to map benthic habitats for fishes, sea turtles, marine mammals and seabirds.[27]
Forestry and land use. Aircraft, both crewed and uncrewed, carry airborne lidar, and the data are used to measure biomass, which informs agricultural, forest and mineral resource assessments.[27]
Transportation. Lidar units mounted on cars and trucks map roads, signs and other transportation infrastructure.[27]
Recommended Reading: Lidar SLAM: The Ultimate Guide to Simultaneous Localization and Mapping
Conclusion
The difference between lidar and radar starts with wavelength. 905 nm is common for automotive lidar, against about 4 mm for 76 to 81 GHz radar. Lidar delivers dense point clouds with centimeter-level precision and angular resolution down to about 0.1°. Radar delivers Doppler velocity measurement, long-range detection, and operation through fog, snow and darkness at lower cost.
That trade-off is narrowing. 4D imaging radar adds elevation and, by its vendors' account, sub-degree azimuth resolution, and FMCW lidar adds per-point velocity. Waymo combines cameras, radar, and lidar, while Tesla relies primarily on cameras. In speed enforcement, the choice is simpler: radar covers the road, lidar targets one car, and NHTSA lists conforming devices of both types.
Frequently Asked Questions
1. Do police use lidar or radar?
Both. NHTSA's Conforming Product List of speed-measuring devices has separate parts for radar and lidar devices that meet its technical specifications. Radar emits a broad beam and works in any weather; lidar uses narrow light pulses to target a specific vehicle.
2. Does Tesla use radar or lidar?
Tesla relies primarily on cameras. It describes its self-driving work as "using primarily vision-based technologies", and its Full Self-Driving (Supervised) support page describes on-board cameras with 360-degree visibility. Tesla's cars carried no lidar in 2019, and Tesla stopped fitting radar to North American Model 3 and Model Y vehicles beginning with May 2021 deliveries.
3. What did Elon Musk say about lidar?
At Tesla's first Autonomy Day event in April 2019, Musk said: "Lidar is a fool's errand. Anyone relying on lidar is doomed. Doomed!" He also called lidars "expensive sensors that are unnecessary". At the same event, Andrej Karpathy, Tesla's Senior Director of AI at the time, called lidar "ultimately a crutch".
4. What can lidar not penetrate?
Lidar is an optical sensor, so anything that blocks or scatters light limits it. Fog is a clear example: below 40 m meteorological visibility, a 2018 benchmark of four lidars found perception limited to less than 25 m. Water absorbs 1550 nm light more than 905 nm light. To measure the seafloor, bathymetric lidar uses water-penetrating green light instead of the near-infrared typical of topographic lidar, and NOAA describes it as used for mapping clear rivers and shallow coastal waters. Like any light, a lidar beam does not pass through opaque solids such as walls.
5. What are the downsides of using lidar?
Higher cost than radar (a 2020 industry view), sensitivity to fog and snow, range that drops with target reflectivity, and no direct velocity measurement unless the sensor is FMCW. Solid-state designs lower cost but typically limit the horizontal field of view to 120° or less.
6. Which is more accurate for autonomous vehicles, lidar or radar?
Lidar is more accurate for position and shape: the InnovizOne automotive lidar lists 0.1° × 0.1° angular resolution with native pixels, and lidar datasheets list centimeter-level range precision. Radar is better for velocity and more reliable in bad weather. Waymo combines both with cameras.
References
What is lidar?, NOAA National Ocean Service, updated September 23, 2026.
Sensor and Sensor Fusion Technology in Autonomous Vehicles: A Review, Yeong, Velasco-Hernandez, Barry and Walsh, Sensors 21(6):2140, 2021.
Inside Aurora's Photonic Engine: Engineering Lidar for Automotive Scale, Aurora Innovation, July 7, 2026.
The fundamentals of millimeter wave radar sensors, Cesar Iovescu and Sandeep Rao, Texas Instruments, SPYY005A, July 2020.
OS1 Mid-Range High-Resolution Imaging Lidar, Hardware Rev8 datasheet, Ouster, 2026.
Under the Hood of Luminar's Long-Reach Lidar, Jeff Hecht, IEEE Spectrum, July 5, 2017.
Airport Surveillance Radar (ASR-11), Federal Aviation Administration, updated September 2025.
First 4D Imaging Radar Sensors for ADAS to Ship in Vehicles in 2021, Nitin Dahad, EE Times, September 2020.
InnovizOne Series Production Unit datasheet, Innoviz Technologies, 2023 (hosted by distributor Level Five Supplies).
The Evolution of 4D Imaging Radar, Huanyu Gu (Director Product Marketing ADAS), NXP Semiconductors, July 31, 2025.
FCC Fact Sheet: Radar Services in the 76-81 GHz Band, Report and Order, ET Docket No. 15-26, Federal Communications Commission, June 22, 2017.
A Benchmark for Lidar Sensors in Fog: Is Detection Breaking Down?, Bijelic, Gruber and Ritter, IEEE Intelligent Vehicles Symposium 2018 (arXiv).
Beginning fully autonomous operations with the 6th-generation Waymo Driver, Waymo, February 12, 2026.
Continental Releases HFL110 3D Flash LiDAR to Series Production, Continental, November 2021.
Radar technology, AUMOVIO.
Aeva Introduces Aeries II, the World's First 4D LiDAR with Camera-Level Resolution, Aeva, February 1, 2022.
nuScenes: A multimodal dataset for autonomous driving, Caesar et al., arXiv, 2019.
Meet the 6th-generation Waymo Driver, Waymo, August 19, 2024.
Anyone relying on lidar is doomed, Elon Musk says, Matt Burns, TechCrunch, April 22, 2019.
Tesla Removes Radar Sensors From Model 3 and Model Y So Autopilot Will Use Cameras Only, Rob Stumpf, The Drive, May 2021 (quoting Tesla's announcement).
Tesla, Inc. Annual Report on Form 10-K for fiscal year 2023, Tesla, January 2024.
Full Self-Driving (Supervised), Tesla Support (Canada), retrieved September 2026.
Conforming Product List (CPL): Speed-Measuring Devices, National Highway Traffic Safety Administration, July 29, 2025.
LIDAR Speed-Measuring Device Performance Specifications, DOT HS 809 811, National Highway Traffic Safety Administration, March 2013.
Police Speed Guns: Differences Between LIDAR and RADAR?, Kustom Signals (speed enforcement equipment manufacturer), undated.
Next Generation Weather Radar (NEXRAD), NOAA National Centers for Environmental Information.
Lidar: Lasers, airplanes, and drones, NOAA National Ocean Service.
in this article
1. Key Takeaways2. Introduction3. A Quick Lidar vs Radar Comparison4. How Lidar Works5. How Radar Works6. 4D Imaging Radar and FMCW Lidar7. Sensor Fusion Combining Cameras, Radar and Lidar 8. Lidar vs Radar in Autonomous Driving9. Lidar vs Radar Speed Guns10. Applications in Air Traffic Control, Weather and Mapping11. Conclusion12. Frequently Asked Questions13. References