What Is Radar? How It Works, Frequency Bands, Types, and Uses
Radar finds objects by sending out radio waves and timing the echo that comes back. This guide explains how radar works from first principles, runs the radar equation with real numbers, and compares the frequency bands, radar types and applications you will meet in practice.

Last updated on 16 Oct, 2026. 16 minutes read
Key Takeaways
Radar (radio detection and ranging) transmits radio waves and listens for the echo. The round-trip time gives range, while the radar also measures the target's angle and size, and the Doppler shift gives its radial speed.[1][2]
Echo power falls with the fourth power of range. To double a search radar's range at the same signal-to-noise ratio, you need 16 times the average power, or an equivalent 12 dB gain elsewhere.[3]
IEEE Std 521 letter bands span HF (3-30 MHz) to W (75-110 GHz). Marine S-band radar (2.9-3.1 GHz) is specified for fog, rain, and sea clutter, while a 77 GHz FMCW radar sweeping 4 GHz resolves objects 3.75 cm apart.[2][4][5][6]
The pulse repetition frequency forcesDoppler dilemma, which means raising the frequency beyond the maximum unambiguous velocity will shorten the maximum unambiguous range.[7]
Radar serves weather forecasting (the US NEXRAD network has 160 S-band Doppler radars), air traffic control, shipping, vehicle safety, and contactless vital-sign monitoring.[8][3][5][9][10]
Introduction
Radar is a sensing technique that uses radio waves to detect objects and determine their distance and velocity. If you’re wondering what is radar? The word comes from the acronym radio detection and ranging.[1]
A radar system sends out its own energy, so it does not depend on daylight. It’s basically a system with long range, all-weather and day/night operation, and three-dimensional target location.[2]
While radars were initially used for air defense, the fundamental properties of these systems paved the way for radar technology for other applications. Today, radars are used for weather forecasting, aviation, shipping, and cars. In this article, you will learn what is radar, how radar works, what limits its range, how the frequency bands and radar types differ, and where engineers use radar today.
What Is Radar?
Radar can be considered an active sensor. It transmits electromagnetic waves and analyzes what comes back. According to the US Federal Communications Commission (FCC), radar operation is described as the transmission of radio frequency (RF) signals and analysis of the reflections from objects or people to determine their speed, range, and direction.[9]
The formal US definition, in 47 CFR § 2.1(c) as quoted by the FCC, calls radar a radiodetermination system based on the comparison of reference signals with radio signals reflected, or retransmitted, from the position to be determined.[9]
What Does RADAR Stand For and What Does it Measure?
RADAR stands for RAdio Detection And Ranging. The technology was developed secretly by several nations before and during the Second World War.[11]
A radar can extract five basic observables from its echoes[2]:
Range: the distance to the target.
Angles: the target's azimuth and elevation.
Size: the target's radar cross section.
Speed: the radial velocity, from the Doppler shift.
Features: finer detail, through imaging.
How Radar Works
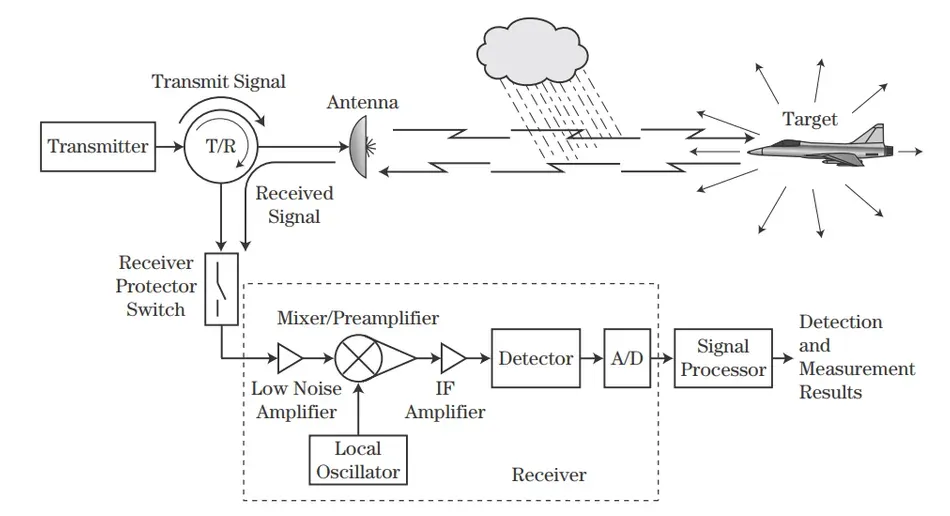
At its simplest, how radar works comes down to timing an echo. The WSR-88D weather radar's transmitter sends brief radio wave pulses instead of a continuous stream of waves, and the system calculates range from the time a pulse takes to reach a target and return.[1]
A pulsed radar system repeats the same sequence for every pulse it transmits:
Generate the waveform. A waveform generator and transmitter produce a burst of RF energy, either a pulse at a single frequency or a pulse whose frequency changes over its length.[2]
Form the radar beam. The radar antenna concentrates the energy in one direction. Its gain is the radiation intensity in that direction relative to an isotropic source, and for an aperture of area A, G = 4πA/λ².[3]
Propagate. The electromagnetic waves travel at the speed of light, about 3 × 10⁸ m/s, and can be attenuated, reflected, and bent by the atmosphere and the ground on the way.[2]
Reflect. The target intercepts part of the energy and scatters some of it back toward the radar. The radar cross section (RCS, σ, in m²) is the measure of how much.[3]
Receive. The radar receiver captures the returning radar signal. In the WSR-88D, the transmitting and receiving antenna is the same.[1]
Process. Signal processing digitizes the echo, compresses the pulse, applies Doppler processing to separate moving targets from stationary clutter, and decides whether a target is present.[2]
Track and display. Tracking and parameter estimation turn detections into radar data on a console or display.[2]
Only a fraction of radio waves are picked up by the receiver, as most of the energy is lost either during propagation or due to scattering. This is the reason why RADARs need a powerful transmitter, a sensitive receiver, and a capable digital signal processor to function properly.
Measuring Range From the Echo
Range follows from the round-trip time τ [2]:
R = cτ/2, where c is the speed of light.
The factor of two is there because the pulse travels out and back. Using this formula, an echo delay of 1 ms places a target 150 km away, and every microsecond of delay adds 150 m.
Range resolution is the ability to separate two targets at nearly the same distance. It is set by the signal bandwidth B [2]:
ΔR = c/2B.
In MIT Lincoln Laboratory's airport surveillance radar example, the 0.6 µs pulse has 1.67 MHz of bandwidth,[3] which gives ΔR of about 90 m (calculated). An FMCW chirp sweeping 4 GHz resolves 3.75 cm.[6]
Received echo energy grows with the time the radar dwells on the target, which demands the need for long pulses. A long pulse on its own cannot measure range accurately, so radar transmits a long pulse whose frequency changes and processes the echo with a matched filter. This is called pulse compression.[2]
Measuring Direction
A radar antenna accentuates radiation in some directions and suppresses it in others.[13] This is how a radar understands a target's azimuth and elevation from where its beam was pointing when the echo arrived.
The antenna size is a critical parameter, and it’s measured in wavelengths. A larger electrical aperture means an increase in gain.[13] MIT's airport surveillance radar example uses a 4.9 m by 2.7 m antenna at 2,800 MHz for a 1.35° azimuth beamwidth.[3]
Speed Measurement with the Doppler Effect
A target moving toward or away from the radar shifts the frequency of the echo. This frequency shift, the Doppler shift, is quantitatively measured as [12]:
fd = 2v/λ
where v is the target's radial velocity and λ is the wavelength.
The Doppler effect is the one you hear from a passing emergency vehicle: sound waves from an approaching source are compressed to a higher pitch and stretched to a lower one as it recedes. The WSR-88D tracks the phase of each pulse and uses the phase shift of the returned wave to determine target velocity.[1]
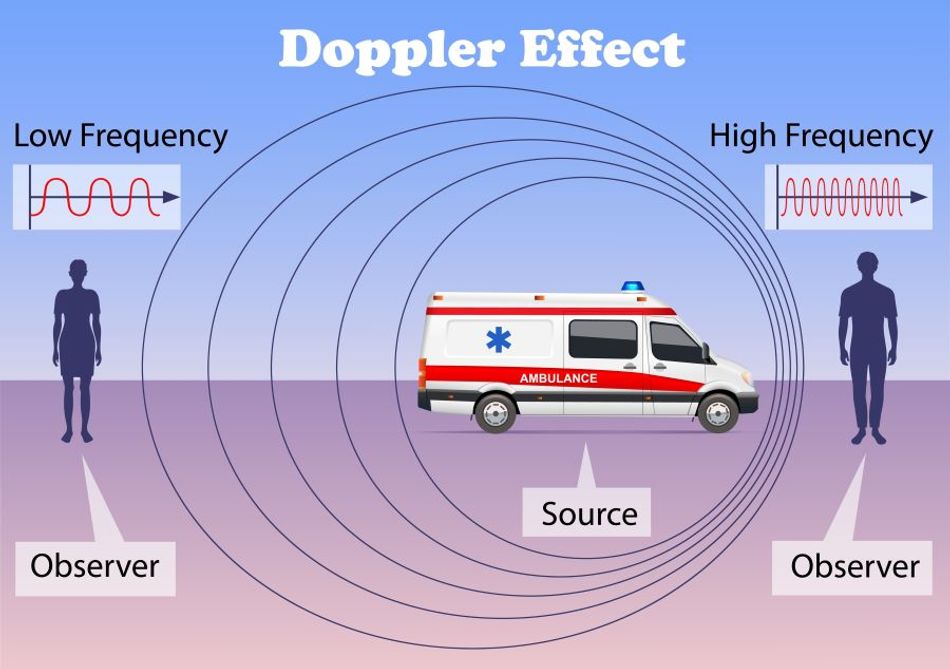
Only the radial component registers. When a wind blows at right angles to the radar's viewing direction, the measured Doppler velocity is zero.[7]
At 77 GHz, the wavelength is about 4 mm.[6] A car closing at 30 m/s (108 km/h) therefore shifts the echo by nearly 15.4 kHz (calculated with λ = 3.9 mm).
Main Parts of a Radar System
Every radar system, from a large surveillance radar to a single-chip automotive sensor, contains the same functional blocks such as RF transmit and receive components, clocking, and digital processing such as analog-to-digital converters and processors.[2][6]
Component | What it does | Example values |
Transmitter and waveform generator | Creates the pulse or chirp and sets peak power | 1.4 MW peak power and a 0.6 µs pulse in MIT's airport surveillance radar example[3]; a synthesizer generating a 77 GHz chirp in FMCW radar[6] |
Radar antenna | Forms and points the radar beam; sets gain and beamwidth | 4.9 m by 2.7 m, 33 dB gain, 1.35° azimuth beamwidth[3] |
Transmit/receive switching | Lets one antenna serve both transmitter and receiver | Transmit/receive switch, circulator and receiver protector, all listed in MIT's radar loss budget[3] |
Radar receiver | Amplifies the weak echo; its noise temperature sets the noise floor | 950 K system noise temperature[3] |
Signal processor | Digitizes the echo, compresses pulses, runs Doppler filters and detection thresholds | A/D conversion, pulse compression, Doppler processing and detection[2]; ADC, MCU and hardware accelerator on one CMOS chip in TI mmWave sensors[6] |
Tracking and display | Turns detections into tracks and radar data | Tracking and parameter estimation, console and display[2] |
The Radar Equation: Why Range Is Expensive
The radar range equation connects target properties (radar cross section), radar characteristics (transmitter power, antenna aperture), the distance to the target, and properties of the medium such as atmospheric attenuation. For a radar pointed at a target whose location is known, the signal-to-noise ratio is given as [3]:
S/N = (Pt × G² × λ² × σ) / ((4π)³ × R⁴ × k × Ts × Bn × L)
Here Pt is peak transmit power, G antenna gain, λ wavelength, σ target RCS, R range, k Boltzmann's constant (1.38 × 10⁻²³ J/K), Ts the system noise temperature, Bn the receiver noise bandwidth, and L the total system losses.[3]
The R⁴ term dominates. The power density falls as 1/R² on the way to the target, and the reflected power density falls as 1/R² again on the way back.[3]
That makes extra range expensive. For a search radar, doubling the range at the same S/N takes 12 dB (16 times) more average power, or the same 12 dB from a larger antenna area, a longer scan time, a smaller search volume, or a larger target.[3] The same law means a 0 dBsm aircraft at 200 km and a -64 dBsm mosquito at 5 km return the same signal-to-noise ratio.[12]
Airport Surveillance Radar as a Working Example
MIT Lincoln Laboratory's course works through an S-band airport surveillance radar looking for a small aircraft with an RCS of 1 m² at a range of 111 km:[3]
Parameter | Value |
Frequency | 2,800 MHz (λ ≈ 0.1 m) |
Peak power | 1.4 MW |
Pulse width and bandwidth | 0.6 µs, 1.67 MHz |
Pulse repetition rate | 1,200 Hz |
Antenna | 4.9 m by 2.7 m, rotating at 12.8 rpm, 1.35° azimuth beamwidth |
Antenna gain | 33 dB with beam-shaping losses (42 dB without) |
System noise temperature | 950 K |
Assumed losses | 8 dB |
Pulses per beamwidth | 21 |
Result | S/N of 1.3 dB per pulse; 14.5 dB after integrating 21 pulses |
A single pulse barely clears the noise. Integrating the 21 pulses in each beamwidth adds 13.2 dB and lifts the result to 14.5 dB, which the course treats as a reasonable S/N for a small aircraft at that range.[3]
Pulse Repetition Frequency and the Doppler Dilemma
A pulsed radar alternates between transmitting and listening. The pulse repetition frequency (PRF) is the inverse of the pulse repetition interval (PRI), the duty cycle is pulse length divided by PRI, and average power equals peak power times duty cycle. A continuous wave radar has a duty cycle of 100%.[2]
The WSR-88D shows how lopsided the timing is. In its usual short-pulse mode, each pulse lasts 1.57 µs and repeats about 1,300 times per second. The radar transmits for a little more than 7 seconds per hour and listens for the other 59 minutes and 53 seconds.[1]
Range Folding
An echo has to return before the next pulse leaves. That sets the maximum unambiguous range [7]:
rmax = c/(2 × PRF)
Echoes from beyond r_max arrive after the next pulse has gone out, and a radar that cannot resolve them folds them back into the first range interval, so a distant storm appears at a false, shorter range.[7] In range-ambiguous radars, strong close targets such as clutter can also mask far, weak targets.[12]
Velocity Aliasing
A pulse-Doppler waveform samples the target once per pulse, at a rate equal to the PRF.[12] The measurable velocity interval, called the Nyquist cointerval, is therefore limited too [7]:
Vmax = ±PRF × λ/4
Multiplying the two limits gives:
Vmax × rmax = ±cλ/8
For a given wavelength, the product is fixed, so increasing rmax decreases Vmax and vice versa. This trade-off is known as the Doppler dilemma.[7]
For illustration, take a PRF of 1,300 Hz and a 10 cm wavelength, which corresponds to 3 GHz.[2] Then rmax is about 115 km and Vmax about ±32.5 m/s (calculated).
A velocity beyond Vmax wraps around. In NSSL's example, with a Nyquist cointerval of ±30 m/s, a 36 m/s wind blowing away from the radar appears as -24 m/s.[7]
Choosing a PRF
Designers pick a PRF class to suit the job, as MIT's course summarizes:[12]
PRF class | Range measurement | Velocity measurement | Notes |
Low PRF | Unambiguous | Very ambiguous | Wind-blown clutter may be a problem |
Medium PRF | Ambiguous | Ambiguous | Ambiguities are the hardest to remove |
High PRF | Very ambiguous | Unambiguous | Far targets compete with near-in clutter |
Radars resolve range and velocity ambiguities by transmitting bursts of pulses at different PRFs and finding the value that agrees across them.[12]
Radar Frequency Bands
Radar engineers have named frequency bands by letter since the Second World War. IEEE Std 521, first issued in 1976 and revised in 1984, 2002 and 2019, was written to remove the confusion caused when other microwave users' letter designations were misapplied to radar.[14]
Radar frequencies sit in the radio part of the electromagnetic spectrum, far below infrared and visible light.[2] The table lists the bands with typical radar uses[2][3][4][5][6][8][9][10]. Wavelengths are calculated from λ = c/f.
Band | Frequency range | Wavelength (calculated) | Typical Usage |
HF | 3-30 MHz | 100-10 m | Early warning; Chain Home operated at 20-30 MHz |
VHF | 30-300 MHz | 10-1 m | Search radars |
UHF | 300 MHz-1 GHz | 100-30 cm | Search radars |
L | 1-2 GHz | 30-15 cm | Search, and search-and-track radars |
S | 2-4 GHz | 15-7.5 cm | Airport surveillance (2,800 MHz), NEXRAD weather radar, marine radar at 2.9-3.1 GHz |
C | 4-8 GHz | 7.5-3.75 cm | Search and track; fire control and imaging |
X | 8-12 GHz | 3.75-2.5 cm | Marine radar at 9.2-9.5 GHz; fire control, imaging and missile seekers |
Ku | 12-18 GHz | 2.5-1.67 cm | Fire control, imaging and missile seekers |
K | 18-27 GHz | 16.7-11.1 mm | Missile seekers |
Ka | 27-40 GHz | 11.1-7.5 mm | Missile seekers |
V | 40-75 GHz | 7.5-4 mm | Industrial and health sensors at 60-64 GHz |
W | 75-110 GHz | 4-2.7 mm | Automotive radar at 76-81 GHz |
The letters can be treated as labels for broad ranges. The actual operating frequencies sit inside narrower ITU allocations. For instance, IMO's standard says marine radar should transmit within the ITU bands allocated for maritime radar.[5] IEEE suggests quoting the ITU radiolocation limits alongside the letter, as in L-band (1.215 GHz through 1.4 GHz).[14]
Further Reading: K Band vs Ka Band: Understanding the Differences and Applications in Modern Engineering
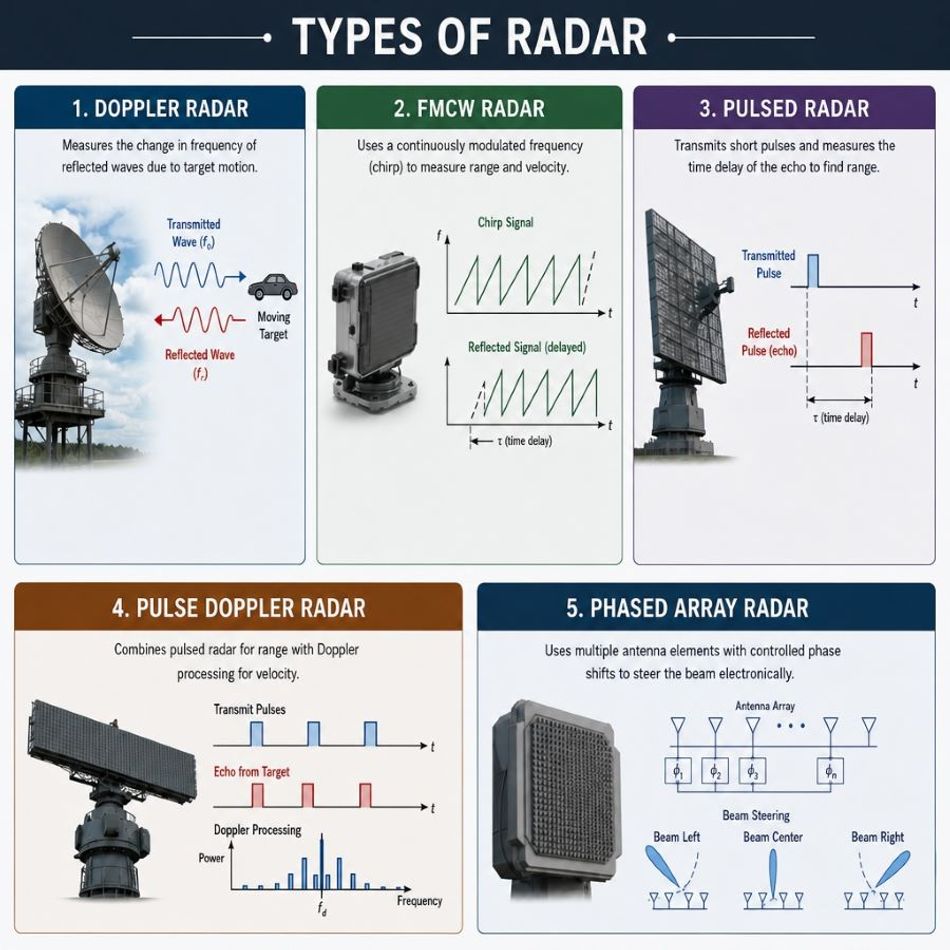
Types of Radar
The main radar types differ in how they transmit and what they extract from the echo.
Pulsed Radar
A pulsed radar transmits brief pulses and listens in between, measuring range from the echo delay. The WSR-88D and MIT's airport surveillance radar example are both pulsed radars.[1][3]
Continuous Wave Radar and FMCW Radar
A continuous wave radar transmits all the time, at a 100% duty cycle.[2] An unmodulated signal carries no timing mark to measure range against, so a plain continuous wave radar is suited to measuring speed from the Doppler shift.
Frequency-modulated continuous wave (FMCW) radar adds that timing mark by increasing its frequency linearly with time in a chirp. TI's description of a 77 GHz FMCW sensor runs as follows[6]: A synthesizer generates a chirp, for example starting at 77 GHz and sweeping 4 GHz in 40 µs, a slope of 100 MHz/µs.
The transmit antenna radiates the chirp.
The receive antenna captures the delayed reflection from each object.
A mixer combines the transmitted and received chirps into an intermediate frequency (IF) signal whose frequency is proportional to distance: f_IF = S × 2d/c.
A Fourier transform separates the IF tones, giving one peak per object.
With a 100 MHz/µs slope, an object 10 m away produces an IF of about 6.7 MHz (calculated).
For velocity, the radar transmits a frame of equally spaced chirps and runs a second, Doppler FFT across them.
Doppler Radar and Pulse-Doppler Radar
A Doppler radar measures the velocity of a target as well as its range.[1] A Doppler weather radar typically reports three base quantities: reflectivity, mean Doppler velocity, and spectrum width.[7]
Two processing families use Doppler to reject clutter.[12]
- Moving target indication (MTI) uses two or three pulses to cancel stationary clutter but does not estimate velocity.
- Pulse-Doppler radar processing uses long waveforms of tens to thousands of pulses, sorts targets into velocity bins, and gives good velocity estimates.[12]
Phased-Array Radar and AESA
A phased-array radar combines many antenna elements, each with its own phase shift, to shape and steer the radar beam electronically.[13] Electronically steered arrays can scan a volume of space faster and more reliably than a mechanically steered radar.[15]
Phased arrays are significantly more expensive than reflector antennas for the same power-aperture; 360° coverage may need three or four array faces, and element spacing must stay below λ/2 to scan without grating lobes. Scanning away from broadside also broadens the beam by 1/cos θ and reduces directivity by cos θ.[13]
Arrays come in two main architectures:
A passive electronically scanned array (PESA) shares a single transmit/receive (T/R) module across all elements
An active electronically scanned array (AESA) dedicates a T/R module to each element.[15]
Applications of Radar
Weather Radar and Tornado Detection
The US NEXRAD network consists of 160 high-resolution S-band Doppler weather radars, operated jointly by the National Weather Service, the Federal Aviation Administration and the US Air Force.[8] All modern weather radars are Doppler radars.[1]
To sample the atmosphere in three dimensions, the WSR-88D steps through as many as 15 elevation angles. During weather, its volume coverage pattern scans 14 angles in about 4.5 minutes.[1]
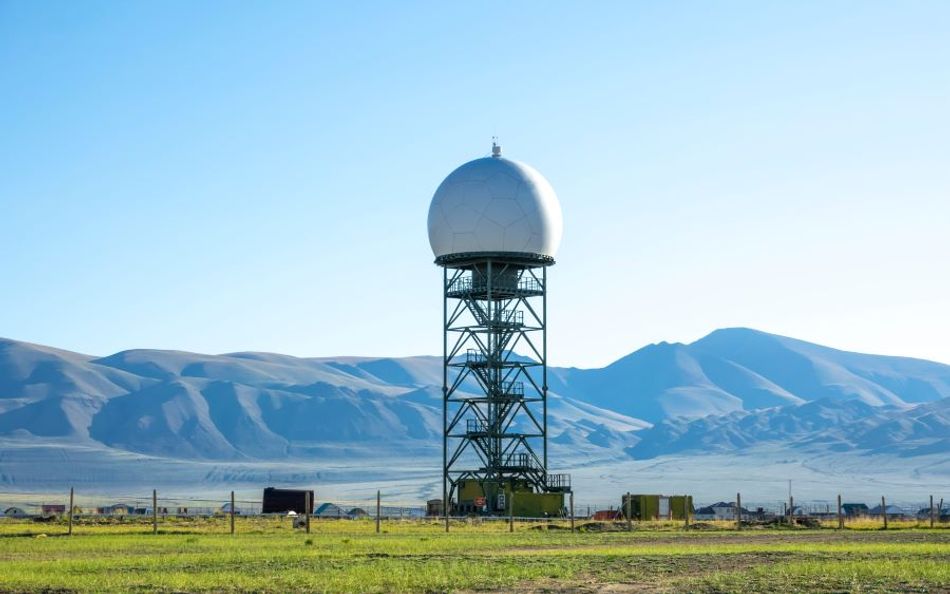
The radar beam gets higher above the ground with distance. At about 160 km from the radar, even the lowest elevation angle of 0.5° is about 3.7 km above the ground.[1]
In 2012, the network was upgraded to dual polarization, so it detects both horizontal and vertical oscillations of each pulse. That helps forecasters clearly identify rain, hail, snow, the rain/snow line, and ice pellets in the precipitation.[1]
At selected airports, the FAA uses Terminal Doppler Weather Radars to monitor wind conditions that would adversely affect aircraft takeoffs and landings.[7]
Air Traffic Control and Aviation
Air traffic control is one of the radar applications MIT's course lists.[2] Its radar equation charts plot several aviation radars: the ASR-9 airport surveillance radar, the ARSR-4 air route surveillance radar, ASDE-3 airport surface detection equipment and the Terminal Doppler Weather Radar.[3]
Airport surveillance radars have to find aircraft in rain and ground clutter. The Moving Target Detector approach applies Doppler filtering to groups of eight or more pulses with a fine-grained clutter map and two PRFs, then rejects birds and ground traffic in post-processing.[12]
Suggested Reading: New radar system can detect drones
Marine Radar
Shipborne marine radar follows IMO performance standards (resolution MSC.192(79)), which apply to radar equipment installed on or after 1 July 2008.[5] The standard covers two bands:[5]
X band (9.2-9.5 GHz) for high discrimination, good sensitivity and tracking performance.
S band (2.9-3.1 GHz) to maintain target detection and tracking in fog, rain and sea clutter.
Its accuracy and resolution requirements show what a navigation radar has to deliver:[5]
Requirement | IMO MSC.192(79) value |
Range accuracy | Within 30 m or 1% of the range scale in use, whichever is greater |
Bearing accuracy | Within 1° |
Range discrimination | Two point targets 40 m apart on the same bearing shown as separate objects |
Bearing discrimination | Two point targets 2.5° apart at the same range shown as separate objects |
Minimum range | A navigation buoy detected from 40 m out to 1 nautical mile (about 1.85 km) |
Start-up | Fully operational within 4 minutes from cold |
An X-band marine radar should also be capable of detecting search and rescue transponders (SARTs) and radar target enhancers.[5]
Automotive Radar
Vehicular radars determine the distance and relative speed of objects in front of, beside or behind a vehicle, helping drivers perceive objects in poor visibility and in blind spots. Long-range vehicular radars support collision avoidance and adaptive cruise control.[9]
The FCC distinguishes two classes:[9]
Long-range radars (LRR) use up to 1 GHz of bandwidth, with spatial resolution on the order of 0.5 m.
Short-range radars (SRR) use up to 4 GHz of bandwidth, with resolution on the order of 0.1 m.
Those typical figures are coarser than the theoretical c/2B limit, which is 15 cm for 1 GHz (calculated) and 3.75 cm for 4 GHz.[6]
Radar vs Lidar vs Sonar
Radar, lidar and sonar all measure range by timing an echo. The difference is the wave they use.[1][2][3][5][8][9][17][18]
Feature | Radar | Lidar | Sonar |
Stands for | Radio detection and ranging | Light detection and ranging | Sound navigation and ranging |
Wave used | Radio waves | Pulsed laser light: near-infrared for land, green for water-penetrating bathymetry | Sound waves, sent as acoustic pulses |
Where it works best | Through the air, in all weather, day or night | Mapping from airplanes and helicopters | Water, where sound travels farther than radar and light waves |
Typical output | Range, angle, radial speed and radar cross section | A dense 3D "point cloud" of elevation points | Range and orientation of objects |
Typical uses | Weather, air traffic control, shipping, vehicles | Shoreline maps, digital elevation models | Nautical charts, seafloor and shipwreck mapping |
Radar and lidar are not the same. Both are active ranging sensors, but radar uses radio waves, and lidar uses pulsed laser light [1][18].
Recommended Reading: Lidar vs. Radar: Comprehensive Comparison and Analysis
Limitations, Common Mistakes and Troubleshooting
Most radar problems trace back to the physics above. Use the table to connect a symptom to its cause [1][2][3][5][7][12][13].
Symptom | Likely cause | What to check or do |
Narrow echoes at short range that do not match anything there | Range folding: echoes from beyond r_max arriving after the next pulse | Lower the PRF or use several PRFs; the WSR-88D's scanning strategies recover range-folded data |
Moving targets vanish at certain speeds | MTI blind speeds at multiples of the PRF | Stagger the time between pulses |
Targets lost in rain, sea or ground returns | Clutter RCS more than 50 dB above the target | Apply MTI or pulse-Doppler processing; on marine radar, use the gain and anti-clutter controls |
Detection range shorter than the radar equation predicts | Unbudgeted losses, such as 2 to 4 dB of beam shape loss or about 3 dB of field degradation | Recheck the loss budget, check the equation dimensionally, and compare the parameters with a real radar |
Spurious beams from a phased array | Grating lobes from element spacing that is too wide | Keep element spacing below λ/2 for full-space scanning |
Weak low-level coverage far from a weather radar | The beam rises with distance from the radar | Account for beam height when you interpret distant echoes |
Three mistakes come up again and again:
Quoting a letter band instead of a frequency. IEEE itself recommends adding the ITU numerical limits in parentheses.[14]
Confusing theoretical and achieved resolution. The c/2B limit is a bound; the FCC's typical automotive figures are coarser.[9]
Forgetting that Doppler sees only radial motion. Wind blowing across the beam reads as zero velocity.[7]
Evolution of Radar Technology
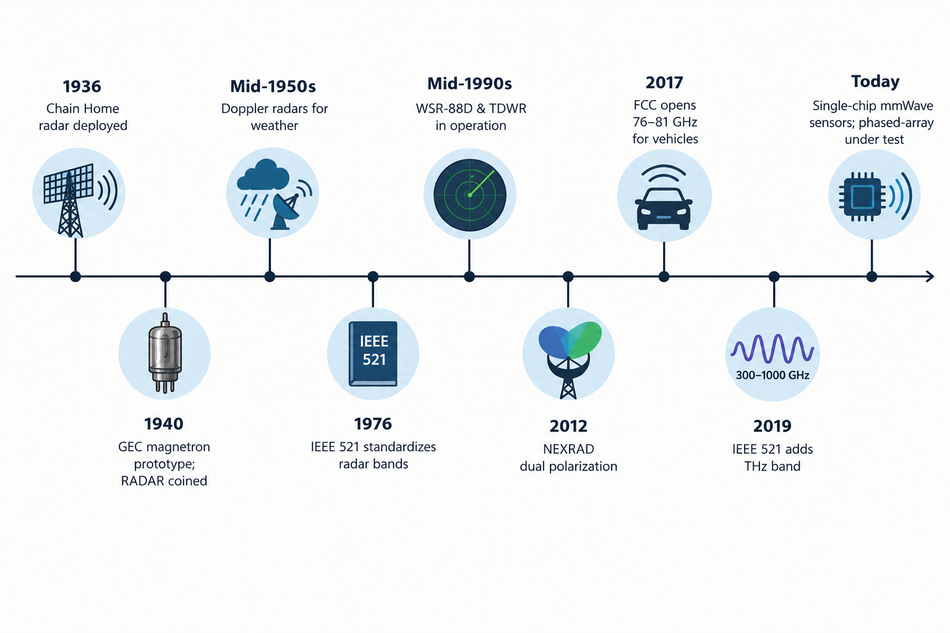
In a span of 90 years, Radar technology has evolved from HF transmitter towers to single chips that can operate at 77 GHz. The GEC cavity magnetron prototype proved to be the game-changer in 1940. It gave the Allies a short-wave portable radar that could locate U-boats in any weather and time of day. This is also the time when the US Navy introduced the term RADAR for this technology. The following figure summarizes the radar evolution timeline.
Conclusion
Radar works on a simple principle. It transmits radio waves, calculates the echo, and reads range, angle, and speed from it. The R⁴ term makes range expensive, the PRF trades unambiguous range against unambiguous velocity, and the frequency band trades antenna size and resolution against weather performance. Those trade-offs explain the landscape, from S-band pulse-Doppler weather radar and X-band marine radar to 76-81 GHz FMCW chips in cars.
Frequently Asked Questions
1. What is radar in simple words?
RADAR stands for radio detection and ranging. It’s a sensor that sends out radio waves and listens for their echoes. From the delay and the change in the echo, it works out how far away an object is, in which direction, and how fast it is moving.
2. How does radar use radio waves?
A radar transmits radio waves in a narrow beam; the waves reflect off objects, and a receiver catches the echo. Range comes from the round-trip time at the speed of light, and velocity from the Doppler shift of the echo.
3. Can radar detect humans?
Yes. Radar reflects from people as well as objects,[9] and 60 GHz mmWave sensors can detect falls and the small chest movements of breathing and heartbeat without contact.
4. What are the main parts of a radar system?
A radar system has a transmitter and waveform generator, an antenna, a receiver, a signal processor, and tracking and display functions.
5. Is radar the same as lidar?
No. Both measure range by timing an echo, but radar uses radio waves and lidar uses pulsed laser light.
6. What are the different types of radar?
The main types are pulsed radar, continuous wave and FMCW radar, Doppler and pulse-Doppler radar, and phased-array radar in passive (PESA) and active (AESA) forms.
7. What frequency does radar use?
IEEE's radar letter bands span HF (3-30 MHz) to W (75-110 GHz), and the 2019 revision adds a THz band for 300-1000 GHz.[2][4][14] Common examples are S band for weather radar and airport surveillance, X band at 9.2-9.5 GHz for marine navigation, and 76-81 GHz for cars.
8. How far can radar see?
It depends on transmit power, antenna size, wavelength and target size, and detection range grows only with the fourth root of those. MIT's airport surveillance example reaches a reasonable signal-to-noise ratio on a 1 m² aircraft at 111 km. At long range, the beam also rises well above the ground.
References
How radar works, NOAA National Weather Service, JetStream.
Introduction to Radar Systems: Introduction (Lecture 1), MIT Lincoln Laboratory
Introduction to Radar Systems: The Radar Equation (Lecture 2), R. M. O'Donnell, MIT Lincoln Laboratory
Radar Band Letter Designations (from IEEE Standard 521-2019), D. Kelley, Bucknell University
Resolution MSC.192(79): Adoption of the Revised Performance Standards for Radar Equipment, International Maritime Organization
The fundamentals of millimeter wave radar sensors (SPYY005A), C. Iovescu and S. Rao, Texas Instruments
A Guide for Interpreting Doppler Velocity Patterns, Chapter 1: Background Information, NOAA National Severe Storms Laboratory.
Next Generation Weather Radar (NEXRAD), NOAA National Centers for Environmental Information
FCC Fact Sheet: Radar Services in the 76-81 GHz Band, Report and Order, ET Docket No. 15-26, Federal Communications Commission
60GHz Radar Sensors Enable Better Health and Medical Care (SWRA810), Texas Instruments application brief
Radar, The Institution of Engineering and Technology, Savoy Place 100 Ideas gallery.
Introduction to Radar Systems: Clutter Rejection, MTI and Pulse Doppler Processing (Lecture 8), R. M. O'Donnell, MIT Lincoln Laboratory
Introduction to Radar Systems: Radar Antennas (Lecture 6), MIT Lincoln Laboratory
IEEE Std 521-2019, IEEE Standard Letter Designations for Radar-Frequency Bands (preview), IEEE Aerospace and Electronic Systems Society, Radar Systems Panel, 2019.
Electronically Steered Array (ESA) Radar, MathWorks.
Multi-function Phased Array Radar (MPAR) Project, NOAA National Severe Storms Laboratory
What is sonar?, NOAA National Ocean Service.
What is lidar?, NOAA National Ocean Service.
in this article
1. Key Takeaways2. Introduction3. What Is Radar?4. How Radar Works5. Main Parts of a Radar System6. The Radar Equation: Why Range Is Expensive7. Pulse Repetition Frequency and the Doppler Dilemma8. Radar Frequency Bands9. Types of Radar10. Applications of Radar11. Radar vs Lidar vs Sonar12. Limitations, Common Mistakes and Troubleshooting13. Evolution of Radar Technology 14. Conclusion15. Frequently Asked Questions16. References